From Map Prediction to Field Evidence: The TruffleMaps Model–Sensor–Evidence–Feedback Loop
· Updated
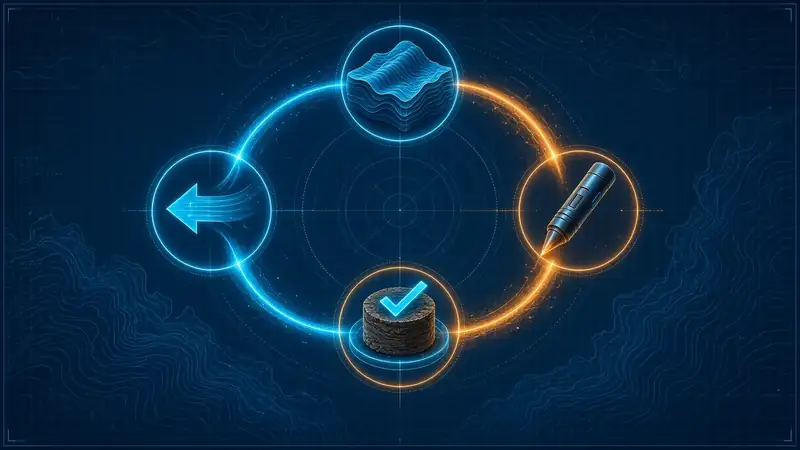
At the heart of TruffleMaps is a four-stage loop: Model → Sensor → Evidence → Feedback. The model decides where to look, TRUFON HUNT detects at that point in the field, the result is recorded as evidence and that evidence improves the next targets. A patent application has been filed for this approach: Patent Application No: 2026/014888.
Why a one-off map is not enough
A static map ages as field reality changes — a dry summer, a new road, a fire clearing — and it never learns what happened in the field.
1. Model
Satellite, soil, geology, topography and habitat data produce habitat layers for four species and priority GPS targets. A habitat score is a relative field priority, never a probability.
2. Sensor: TRUFON HUNT
At the target, TRUFON HUNT performs field detection. The sensor is not an optional add-on but the centre of the loop — the link that turns a target on the map into evidence in the field.
3. Evidence
Every measurement, excavation and outcome is recorded with location and time. Negative visits are evidence too.
4. Feedback
Evidence flows back into the model: zones that keep coming back negative lose priority; targets near verified findings move up.
Results
TruffleMaps/TRUFON field work using this loop has achieved an 85% successful excavation rate, based on targeted excavation results. In a real field test, Tuber aestivum was found at all three preselected GPS target locations (field evidence).
Auditable decisions
For forestry operations the loop means auditable decisions: why a target was chosen, which visits were negative and why priorities changed (institutions).
Next step
Read about the patent technology or the end-to-end workflow in Target on the Map, Detection in the Field, and request access.